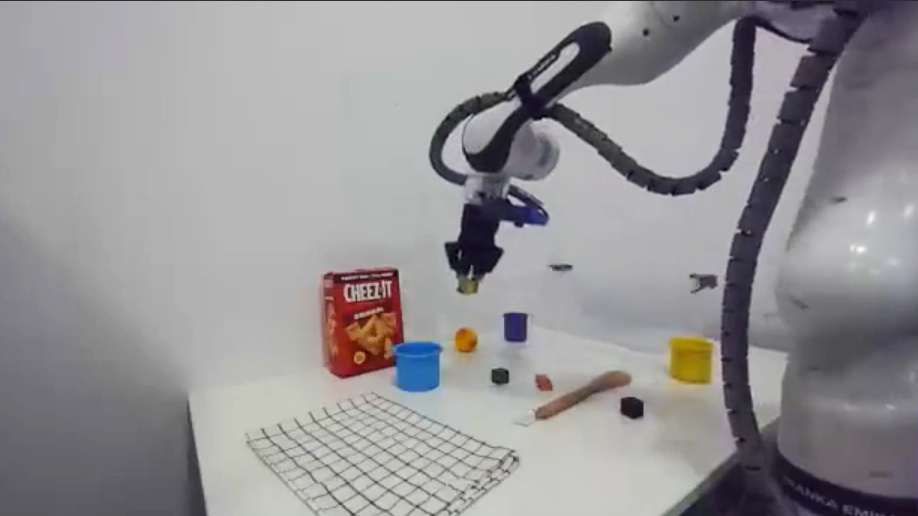
American generative AI company Runway, which develops the video generation AI “Runway” series, video editing AI “Aleph 2.0,” and more, has announced “Praxis-1,” an open-weight world action model that converts video pretraining into control of real robots.
Praxis-1: From Video Pretraining to Robot Control | Runway Research
https://runway.com/research/praxis-1-video-pretraining-to-robot-control
Today, we’re making Praxis-1 available to everyone. Our state-of-the-art world action model turns video pretraining into control for real robots, and it ships with open weights under Apache 2.0, ready to run and fine-tune on your own hardware. pic.twitter.com/jL5ZmpY6x9
— Runway (@runwayml) November 11, 2026
Runway Praxis-1 Is Now Available: Open-Weight Robotics Model
https://runway.com/news/company-news/praxis-1-is-now-available
Developing robot-control AI requires large amounts of “data on robot movement,” but collecting the data is extremely costly. Runway therefore reasoned that “the most scalable source of data is ordinary videos that people record in their everyday lives,” and trained an AI model to predict object behavior, hand movements, work activities, and more from video.
This is how Praxis-1 came to be. Praxis-1 is based on Runway’s video foundation model, which has 27 billion parameters, and can be run locally. An NVFP4 quantized model capable of running on an NVIDIA GeForce 5090 is also available.
.@Runwayml’s Praxis-1 is a 27B-parameter open-weight world action model that is optimized to run locally on NVIDIA RTX 5090.
— NVIDIA RTX Spark (@NVIDIARTXSpark) November 11, 2026
Praxis-1 is a leading world action model on NVIDIA’s RoboLab-120 leaderboard.
Download the NVFP4 checkpoint on Hugging Face: https://t.co/ZPN2Kw7ww7 https://t.co/DJ2gs84w0f
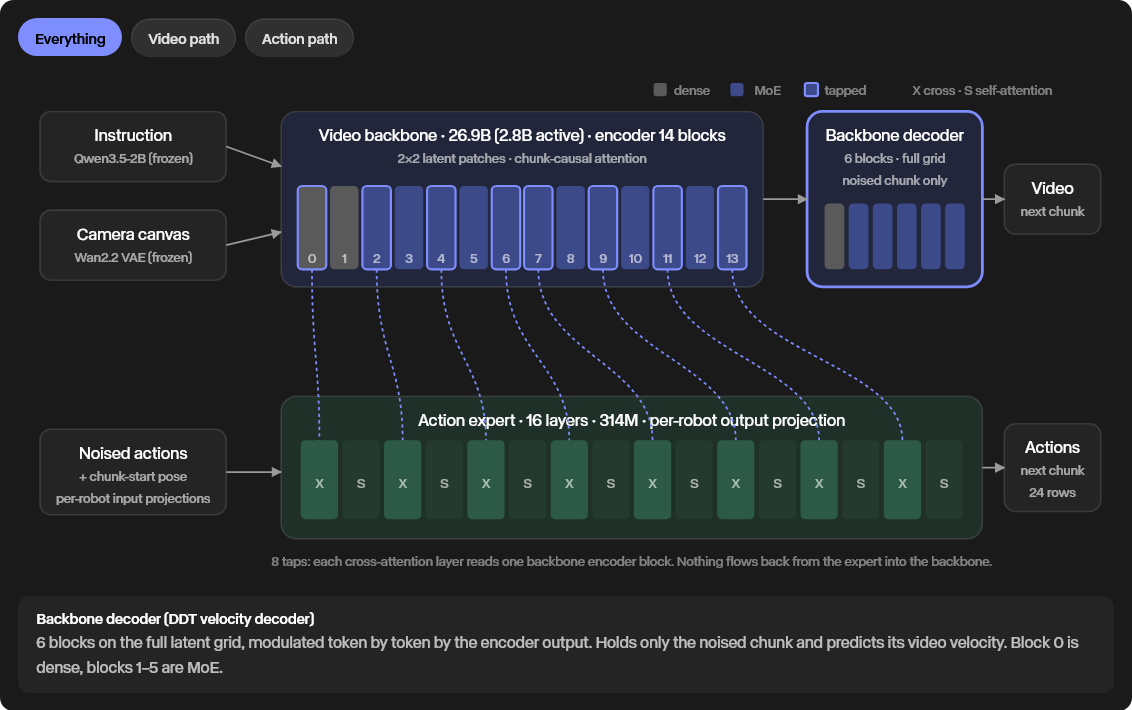
Praxis-1 has been transformed into an “open-weight world model” that predicts the future in short increments. A compact action expert reads the internal states of a video foundation model and imagines what will happen next. Each time the robot acts, Praxis-1 predicts both what the scene will look like and the movements required to reach it. By incorporating a step of “learning how the world works from video” before learning specific actions, it functions as a broadly adaptable model for robotics.
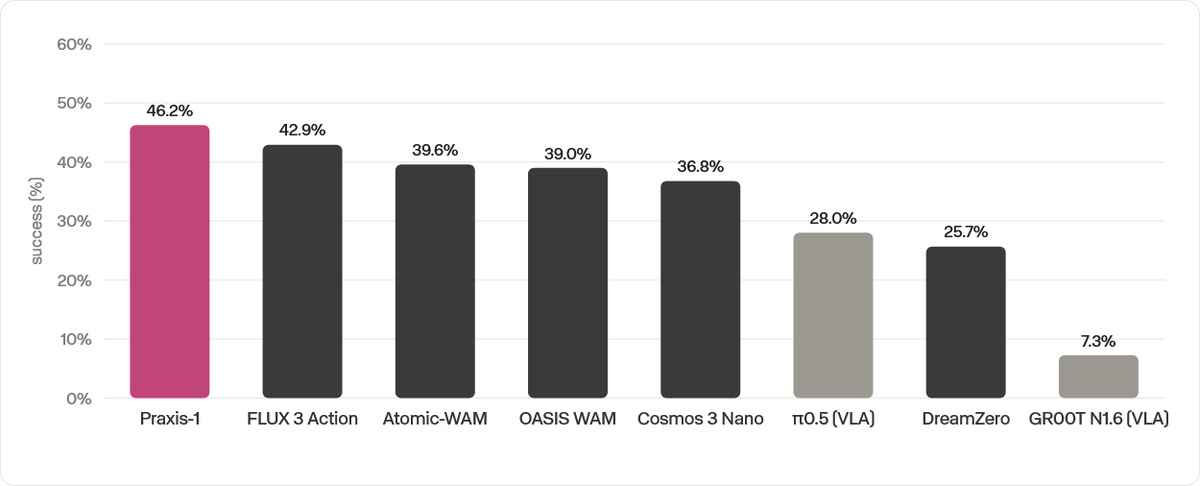
To evaluate Praxis-1, the researchers used “Robolab-120,” a benchmark for robot control, and the robotic arm of “FRANKA RESEARCH 3,” a robotic system specializing in robotics and AI. Praxis-1 is reported to have solved 555 of the 1,200 scenarios (46.2%), achieving the highest score in both the “world action model” and “open-source robot foundation model” categories on the leaderboard. On tasks using FRANKA RESEARCH 3 across the 10 individual scenarios published by “FLUX 3 Action,” the robot-control world action model that had previously recorded the highest score, Praxis-1 scored “88,” surpassing FLUX 3 Action’s “80.”
In addition, state-of-the-art multimodal models can now drive robotic arms in a zero-shot manner through tools and code interfaces. “GPT-6 Astra,” announced by OpenAI in September 2026, achieved a 22.5% success rate on the robotic object-manipulation benchmark “RoboDojo,” surpassing all publicly listed entries and taking the lead on the Robolab-120 leaderboard. However, multimodal models have the disadvantage of latency and cost when compared with world action models. In fact, when Runway ran Praxis-1 and GPT-6 Astra on the same three tasks, GPT-6 Astra took 15.6 times as long to complete tasks on average and cost 51 times as much per completed task.
Runway has published several videos of Praxis-1 and FRANKA RESEARCH 3 performing tasks such as “putting a specified item into a bag or a designated dish,” “placing a mug upside down on a tray,” and “closing the lid of a box.” Runway emphasizes that “it is important not only to top the benchmark scores, but also to demonstrate practical examples of real robots carrying out everyday tasks.”
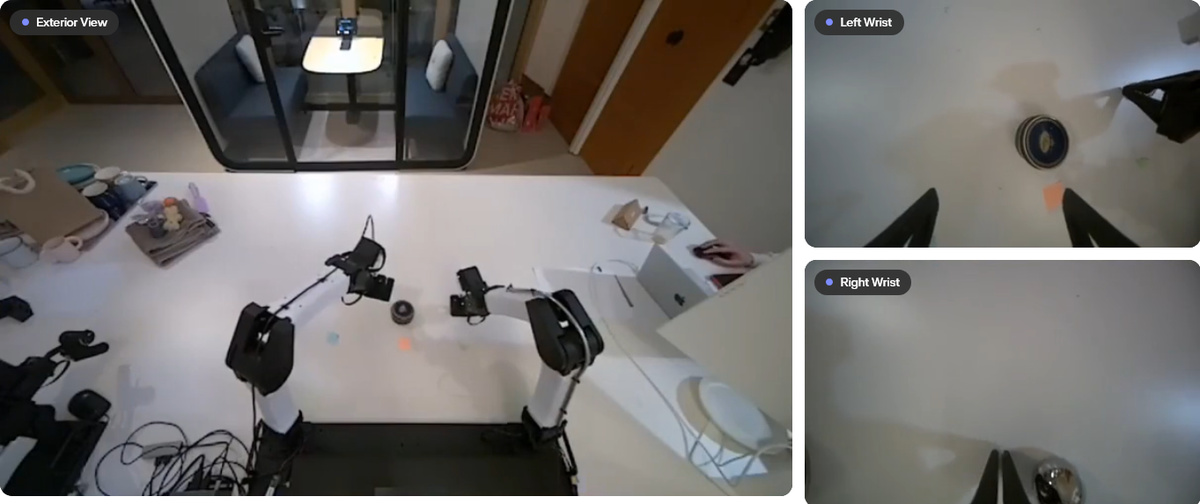
Runway says, “We want to understand whether a model’s ability to predict its own future is also a sign of task success. These test results are still at an early stage, but they nevertheless show the direction we value most.It is a model that learns from its own video predictions by using imagined futures to evaluate and improve its own actions. We are actively researching this direction in pursuit of world action models that truly self-improve. We will continue to invest in research into world action models, focusing particularly on long-term thinking, autonomous planning, and self-improvement loops,” he said.
Praxis-1 is publicly available on Hugging Face under the Apache License 2.0.
Praxis-1 - a runwayml Collection
https://huggingface.co/collections/runwayml/praxis-1
The related code is also publicly available on GitHub.
GitHub - runwayml/praxis-1-oss · GitHub
https://github.com/runwayml/praxis-1-oss



