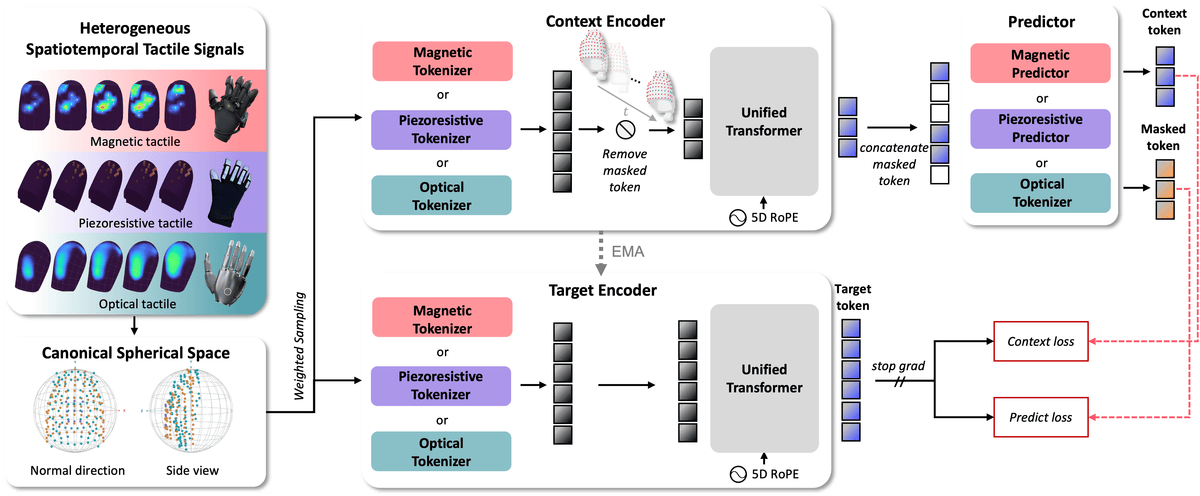
On November 10, Ant Lingbo Technology open-sourced the tactile foundation model LingBot-Touch On November 10, Ant Lingbo Technology open-sourced the tactile foundation model LingBot-Touch, filling a critical gap in tactile perception for robot brains. The model was pre-trained on nearly 5,000 hours of real tactile data and covers three mainstream sensing principles: magnetic tactile sensing, vision-based tactile sensing, and piezoresistive sensing. It can